Sample project
Raw capture clean-up: 900 frames in, 478 worth labeling
Data processing
- Data
- Video · 1920×1080, sampled at 10 fps
- Volume
- 900 frames from 3 clips
- Status
- Sample project
The problem
Raw robot-learning video is mostly repetition: at 10 frames a second, most neighbouring frames are nearly identical, and transitions and fast motion leave frames too soft to label. Labeling all of it wastes budget.
What we did
- Sampled three 30-second raw clips at 10 fps
- Scored every frame for sharpness (variance of the Laplacian) and near-duplication (difference hash)
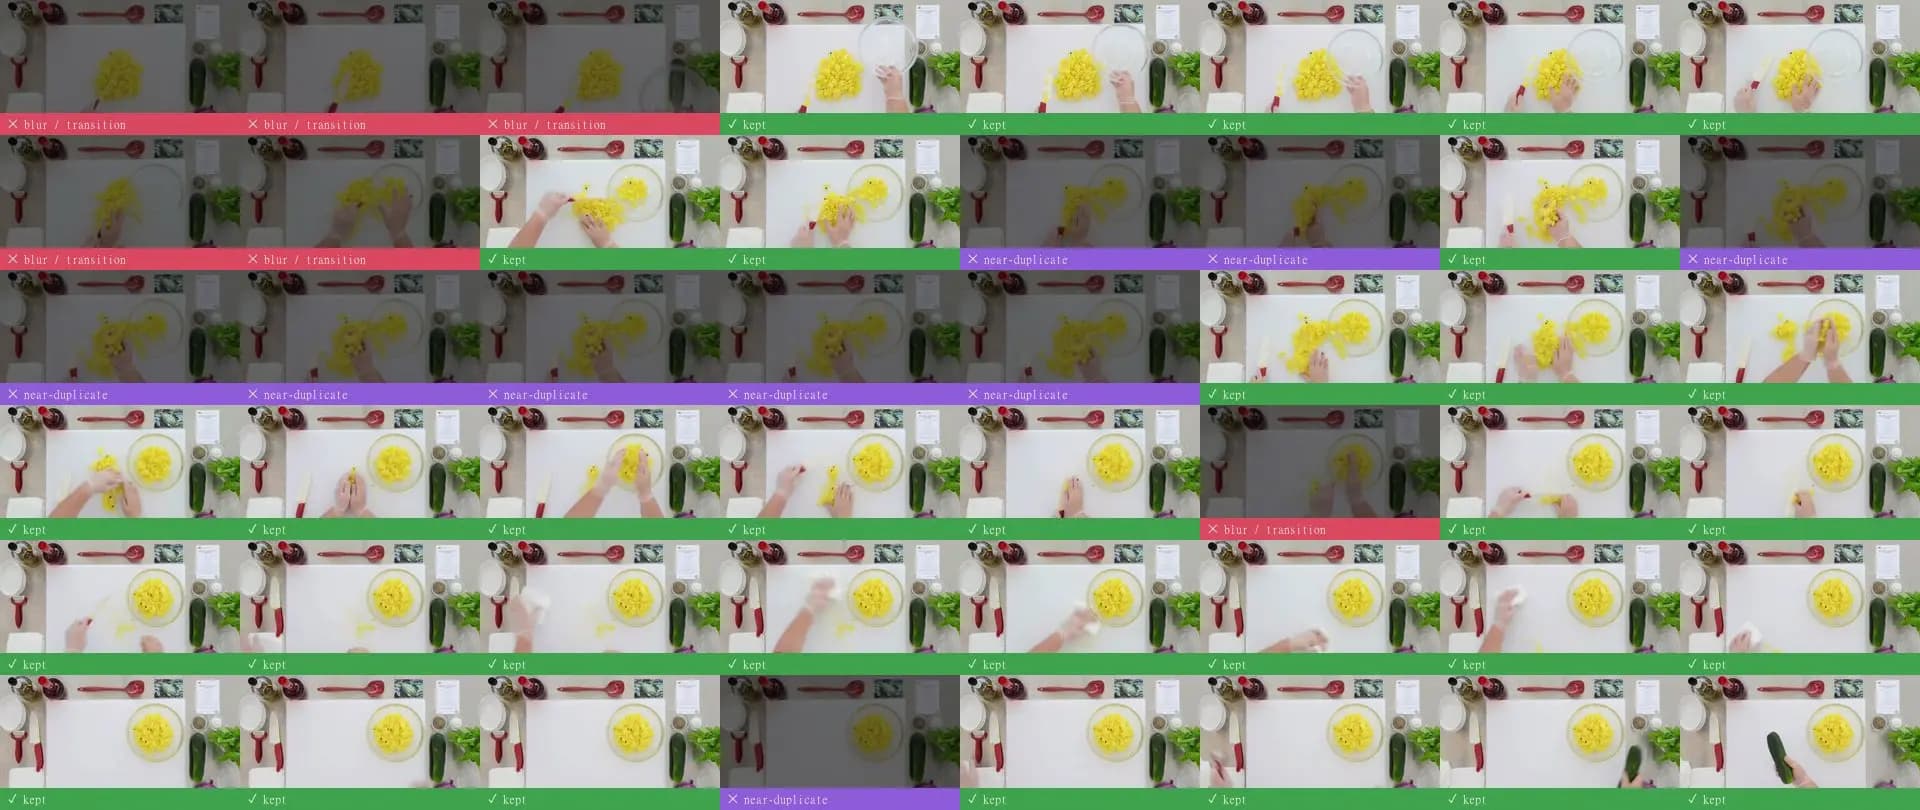
- Removed 332 near-duplicates and 90 blurred or transition frames
- Normalised colour and exposure on the frames we kept
- Logged the verdict and scores for every frame
Result
478 of 900 frames kept for labeling (47% fewer to pay for), with a per-frame log of what was removed and why.
Frames and their verdicts
Sample output
The first rows of the per-frame log delivered with the cleaned set: brightness, sharpness and the verdict for every frame.
cleanup.csvexcerpt
frame,mean_luma,sharpness,verdict
01-f0003,182.5,216.0,kept
01-f0053,176.3,214.5,rejected: near-duplicate
01-f0001,181.3,209.3,rejected: blur / transition
Source: our three raw 30-second overhead clips (the unlabeled source video of the kitchen samples). Frame scoring, filtering and normalisation by Annoroid.