Skip to content
annoroid

Our work

Real output, not mockups of it

Every sample here is our own work on public-domain or CC0 footage. Drag the line on any image to compare the raw frame with what we delivered.
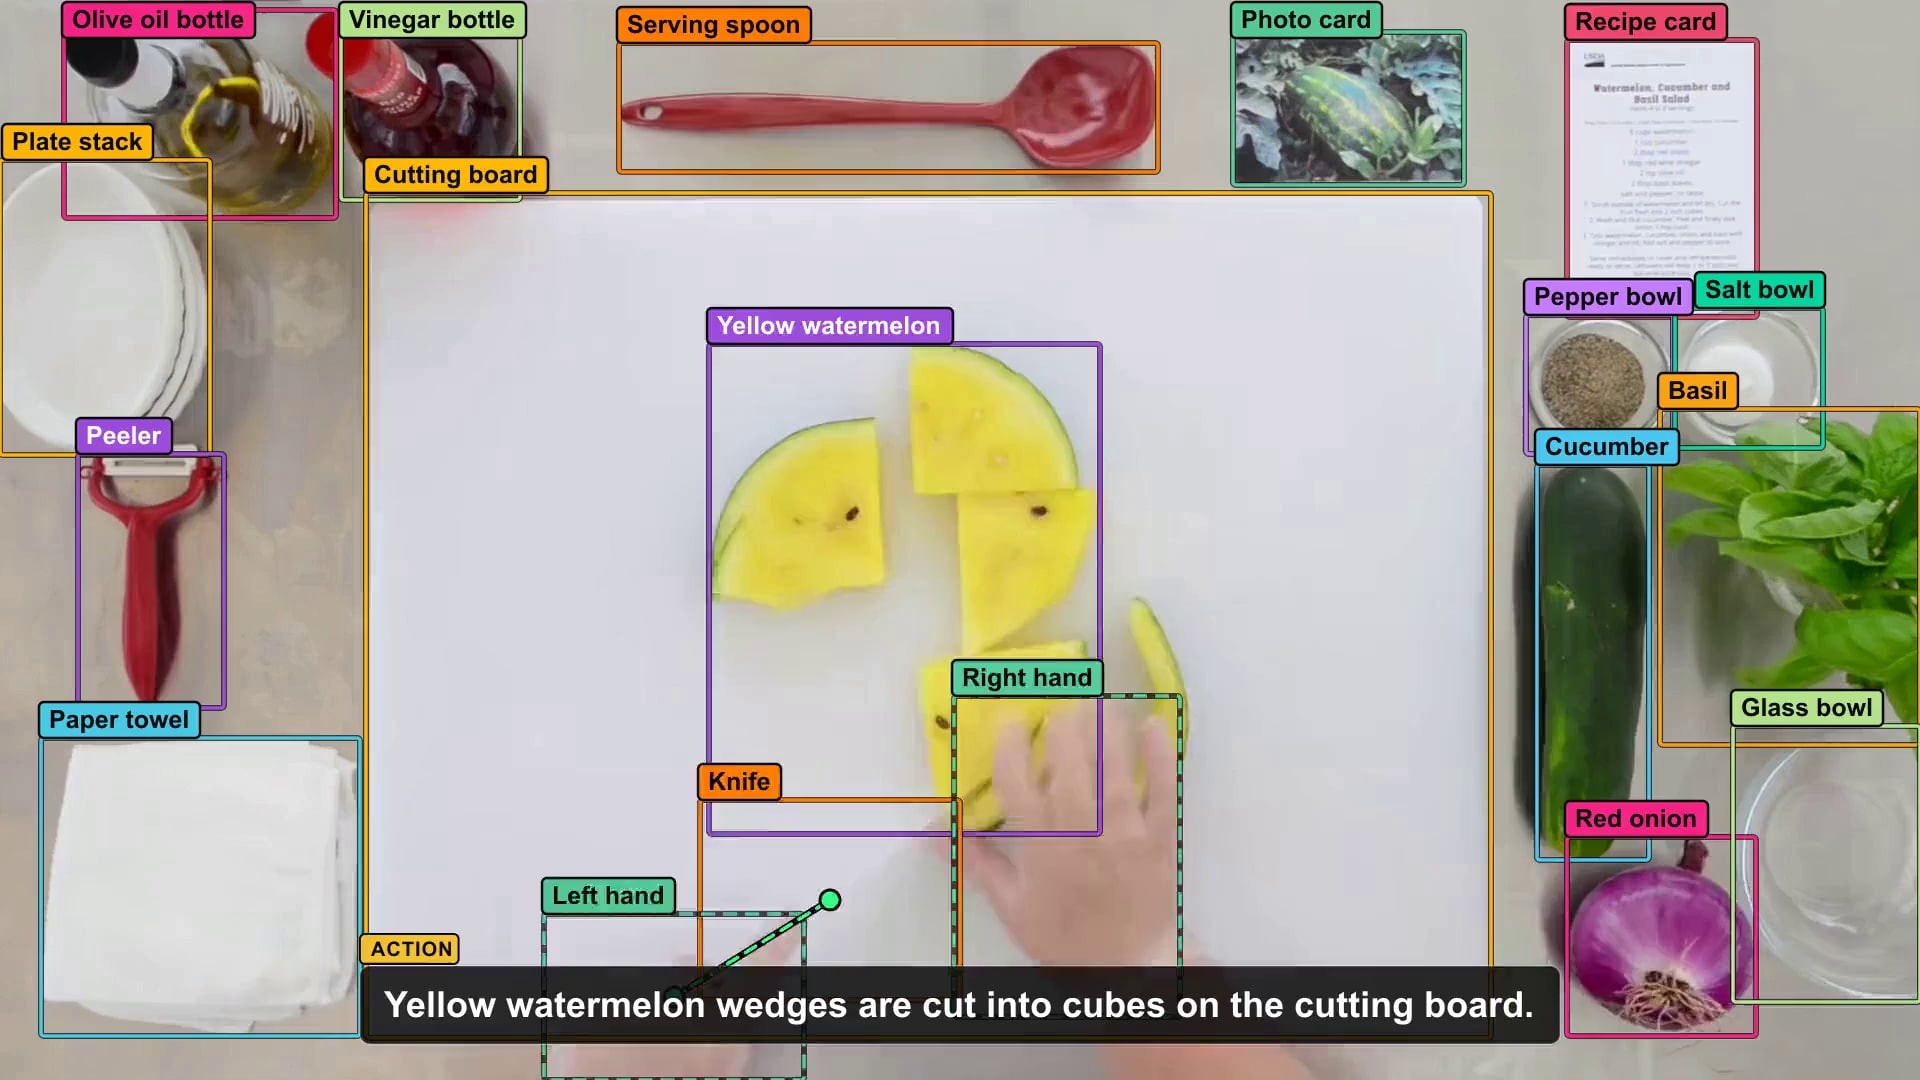
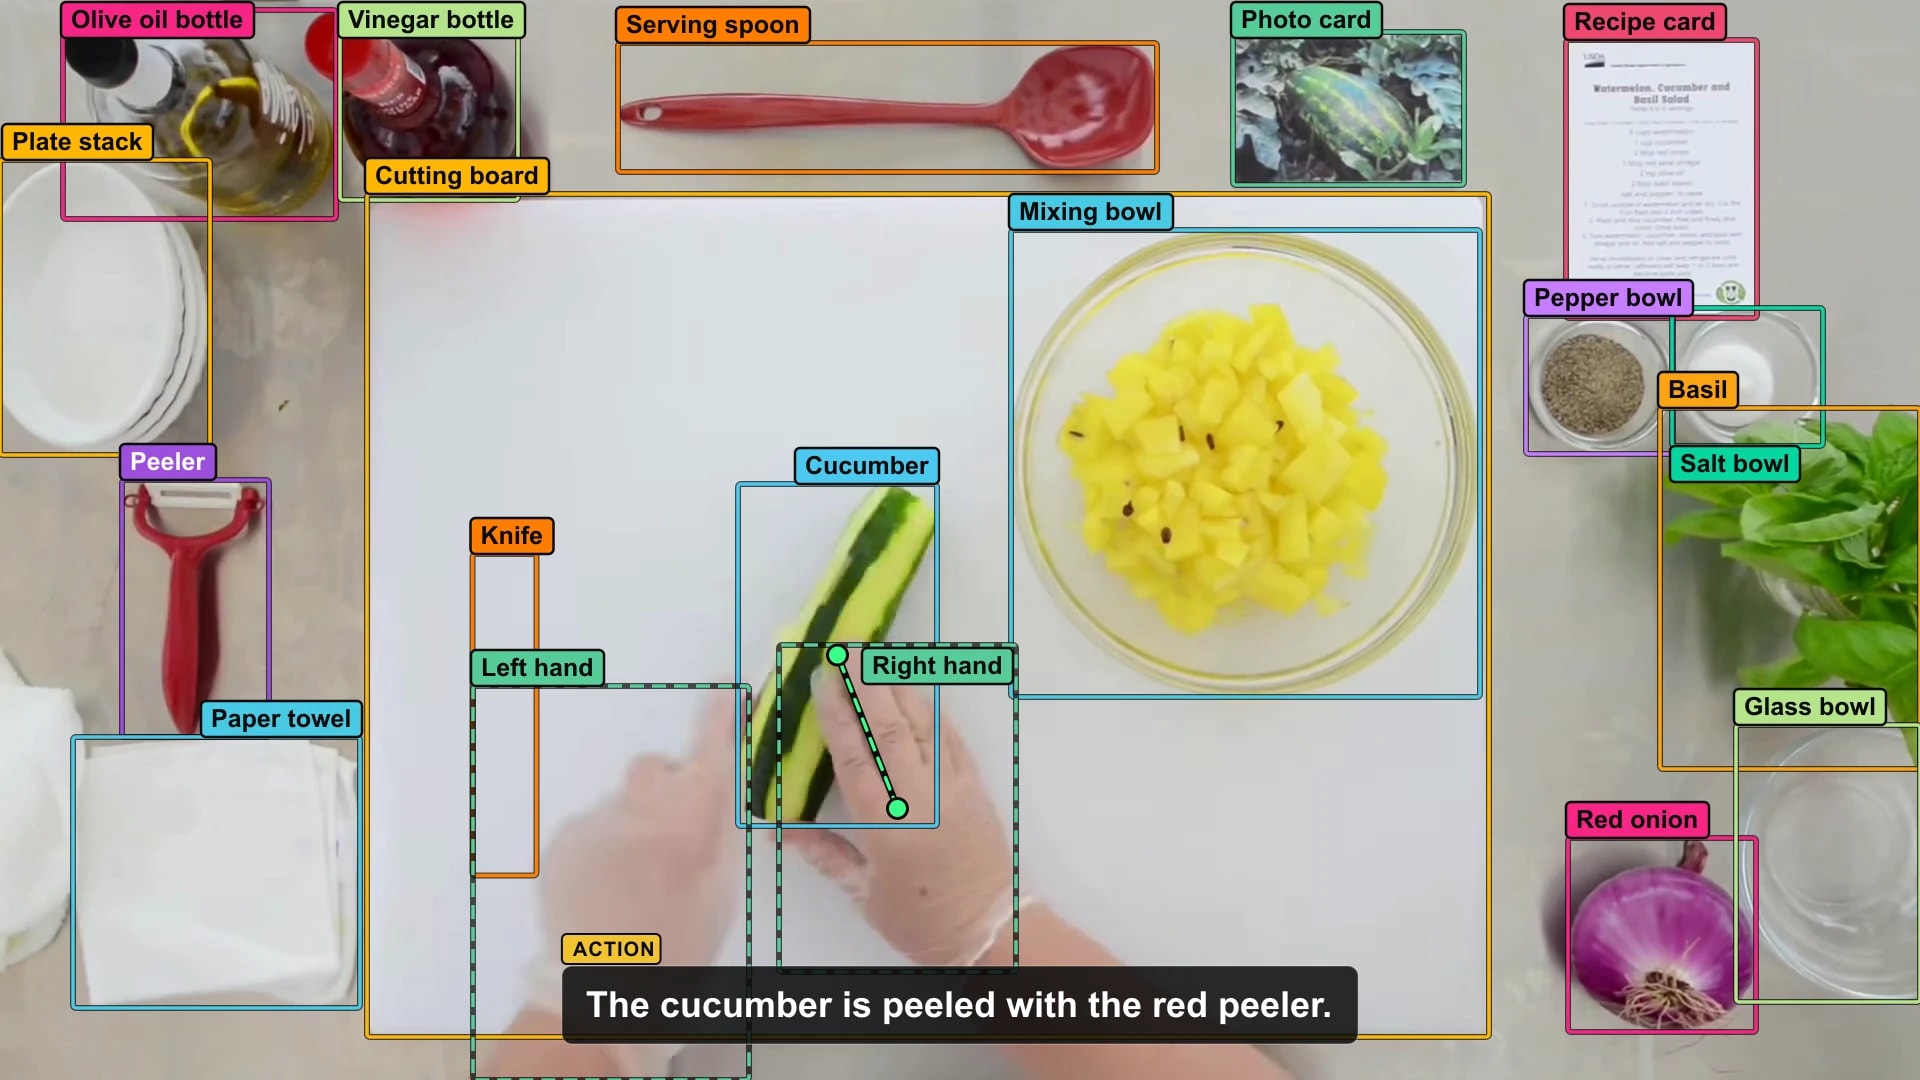
Live output · watermelon salad · tracks, contacts and actions, frame by frame

Audit of a public dataset

We audited a public robot dataset. Here is what we found.

lerobot/aloha_static_coffee (MIT) · 50 episodes · 55,000 frames · 4 cameras · 14-joint state, action and effort at 50 fps.

Clean capture. The gap is label depth, and one gripper worth a calibration check.

Every number comes from the dataset's own files. The audit script is in our repo.

  • Timestamp gaps (expected 20 ms steps)0 gaps in 55,000 frames
  • Episode boundaries and done flags50 of 50 correct
  • Camera video vs joint data alignment200 of 200 camera segments aligned
  • Frozen sensor frames (identical consecutive state)63 repeated readings across 30 episodes; at most 5 identical in a row (0.08 s)
  • Idle time at episode ends5.1 s in total; longest ep 31 (0.78 s)
  • Gripper tracking (commanded vs measured)Left gripper differs 0.038–0.116 rad vs 0.007–0.038 on the right; left is over 2× the right in 43 of 50 episodes
  • Label depthOne task sentence for all 50 episodes; no step boundaries, contacts or per-step instructions

What we would deliver on this dataset

Task: “Place the coffee capsule inside the capsule container, then place the cup onto the center of the cup tray, then push the 'Hot Water' and 'Travel Mug' buttons.”

  • Seven step boundaries per episode, from pick up the capsule to pressing the buttons
  • Gripper contact and release events for the capsule and the cup
  • Low-level instructions per step under the dataset's own task sentence
  • A calibration note on the left gripper, with the episodes most affected

Watch the previews

Each reel is 30 seconds of our output: tracks, hand contacts and captions as delivered.

Proven on real footage

Watch the video previews
Overhead kitchen task: 20 object tracks, hand contacts and action captions — raw frame and labeled output
RAWANNOROID

Overhead kitchen task: 20 object tracks, hand contacts and action captions

Read case study
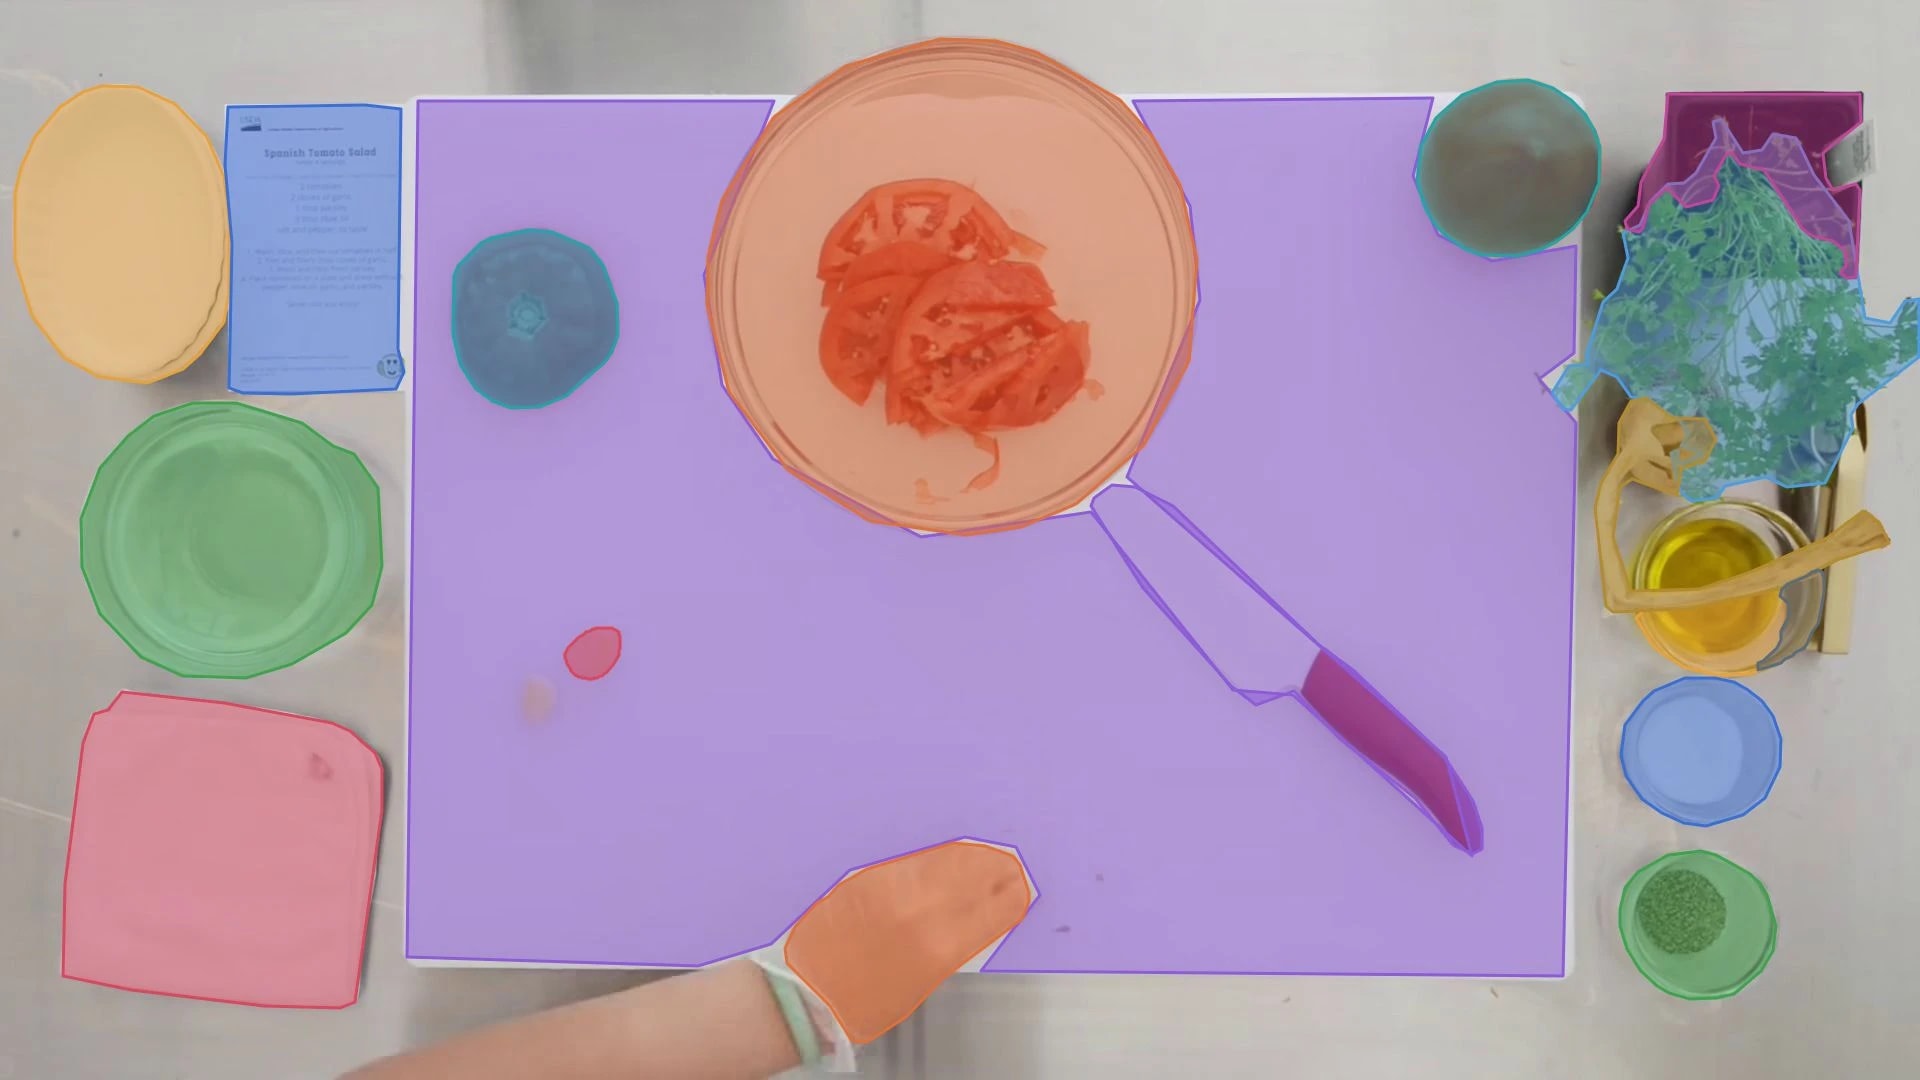
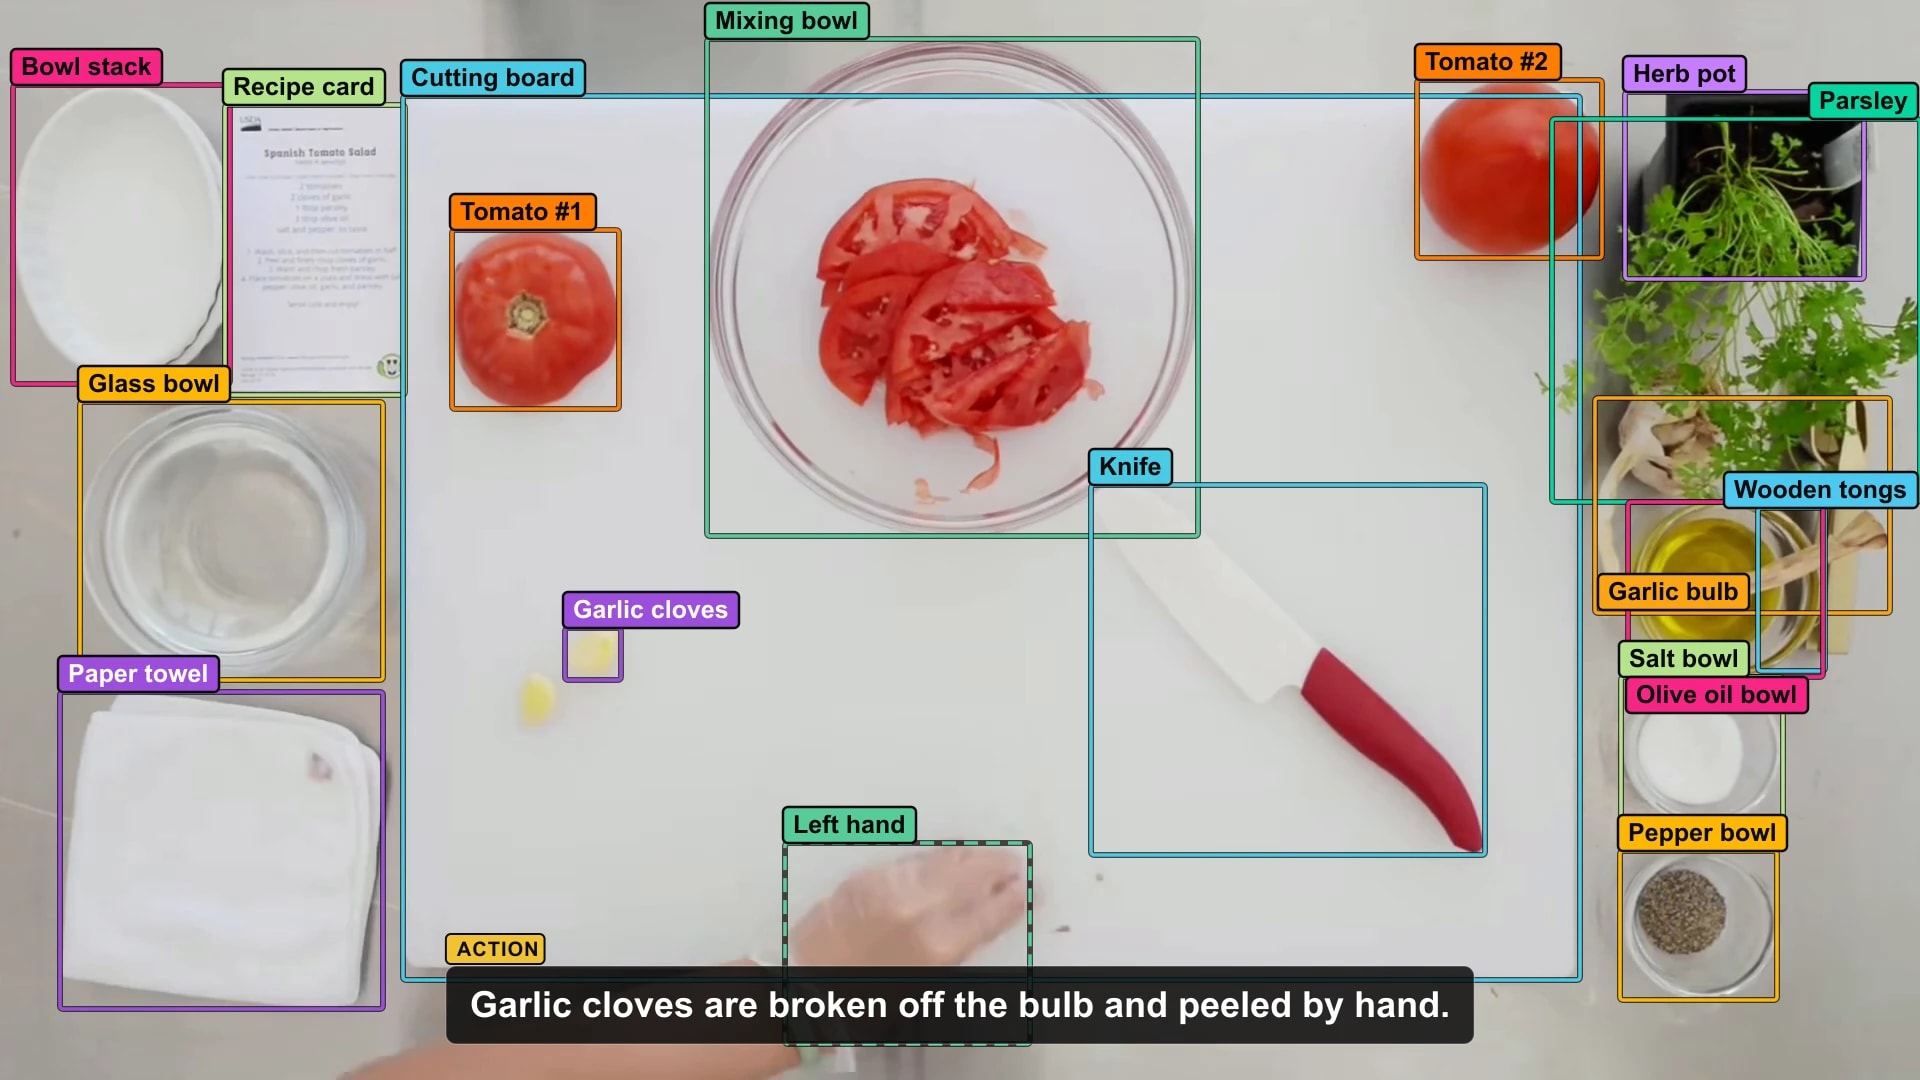
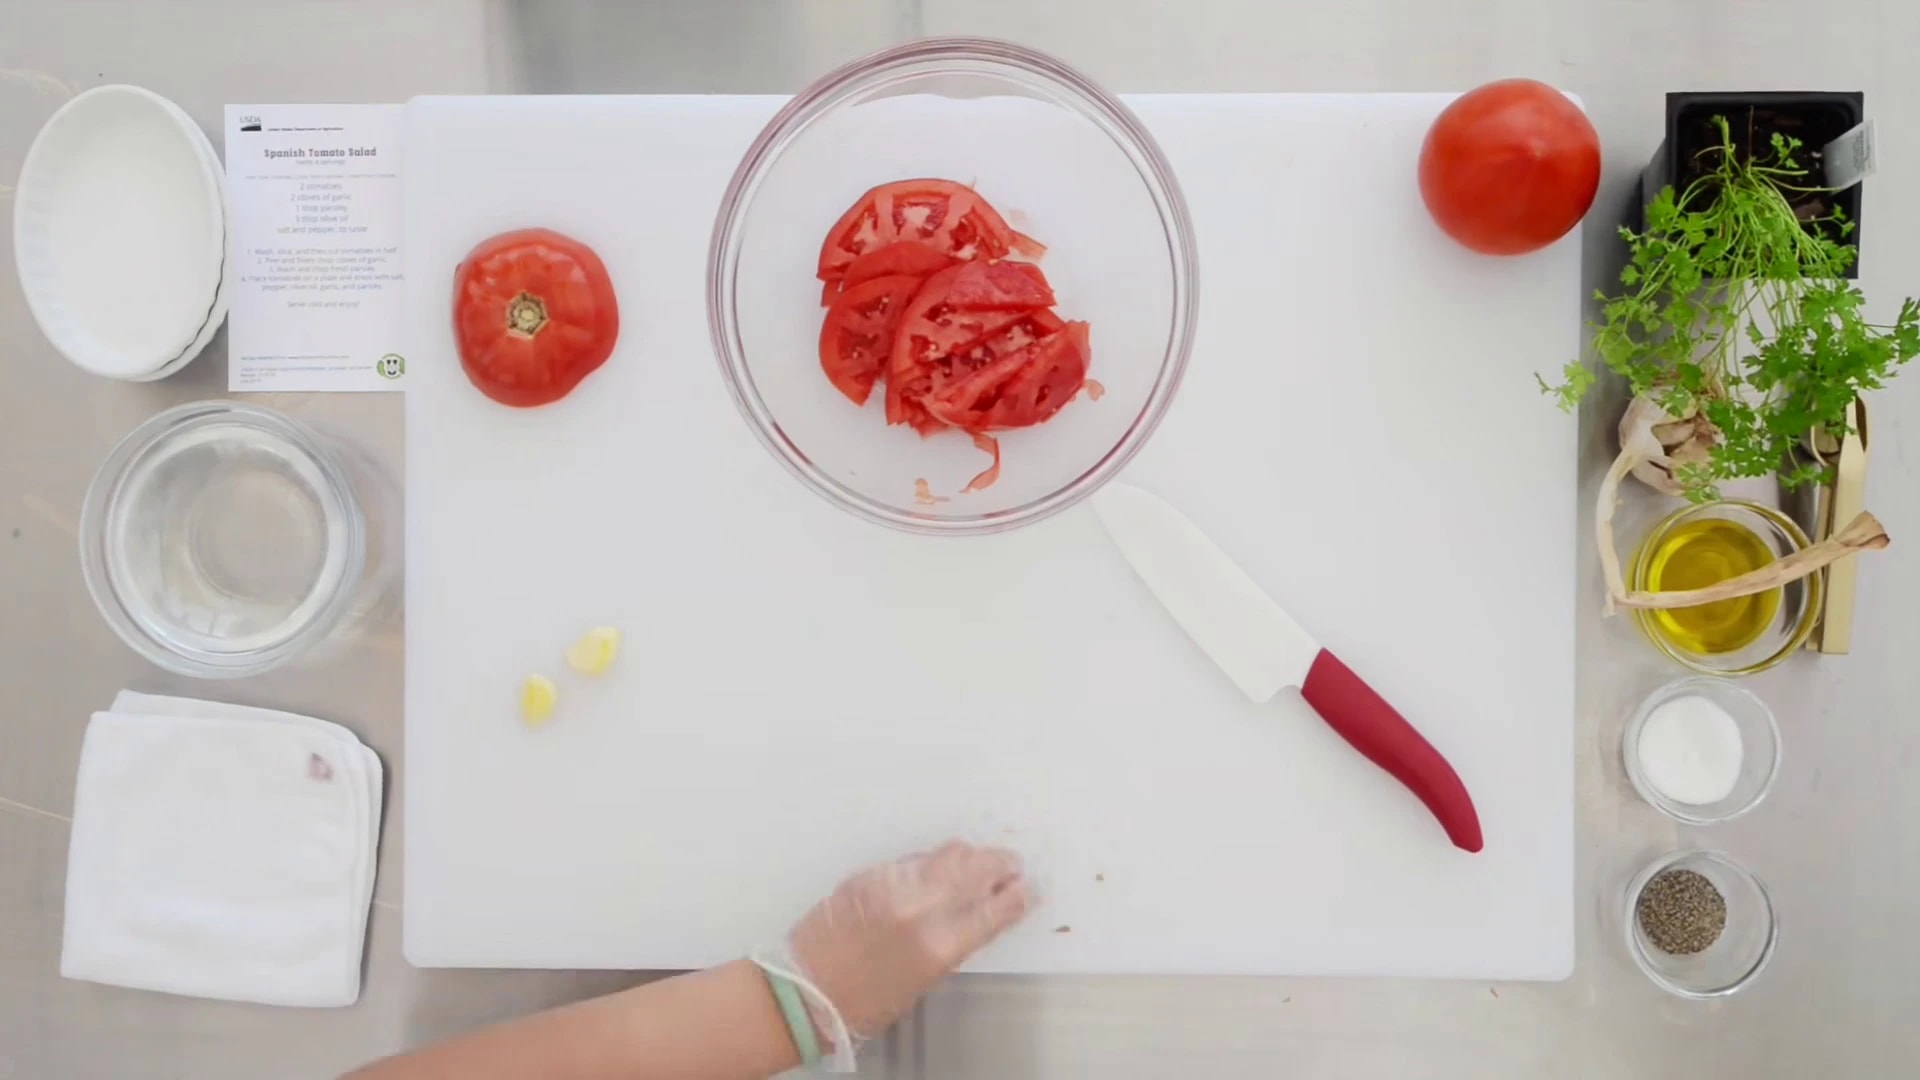
Tomato salad prep: tracking through occlusion, with hand-object relationships — raw frame and labeled output
RAWANNOROID

Tomato salad prep: tracking through occlusion, with hand-object relationships

Read case study
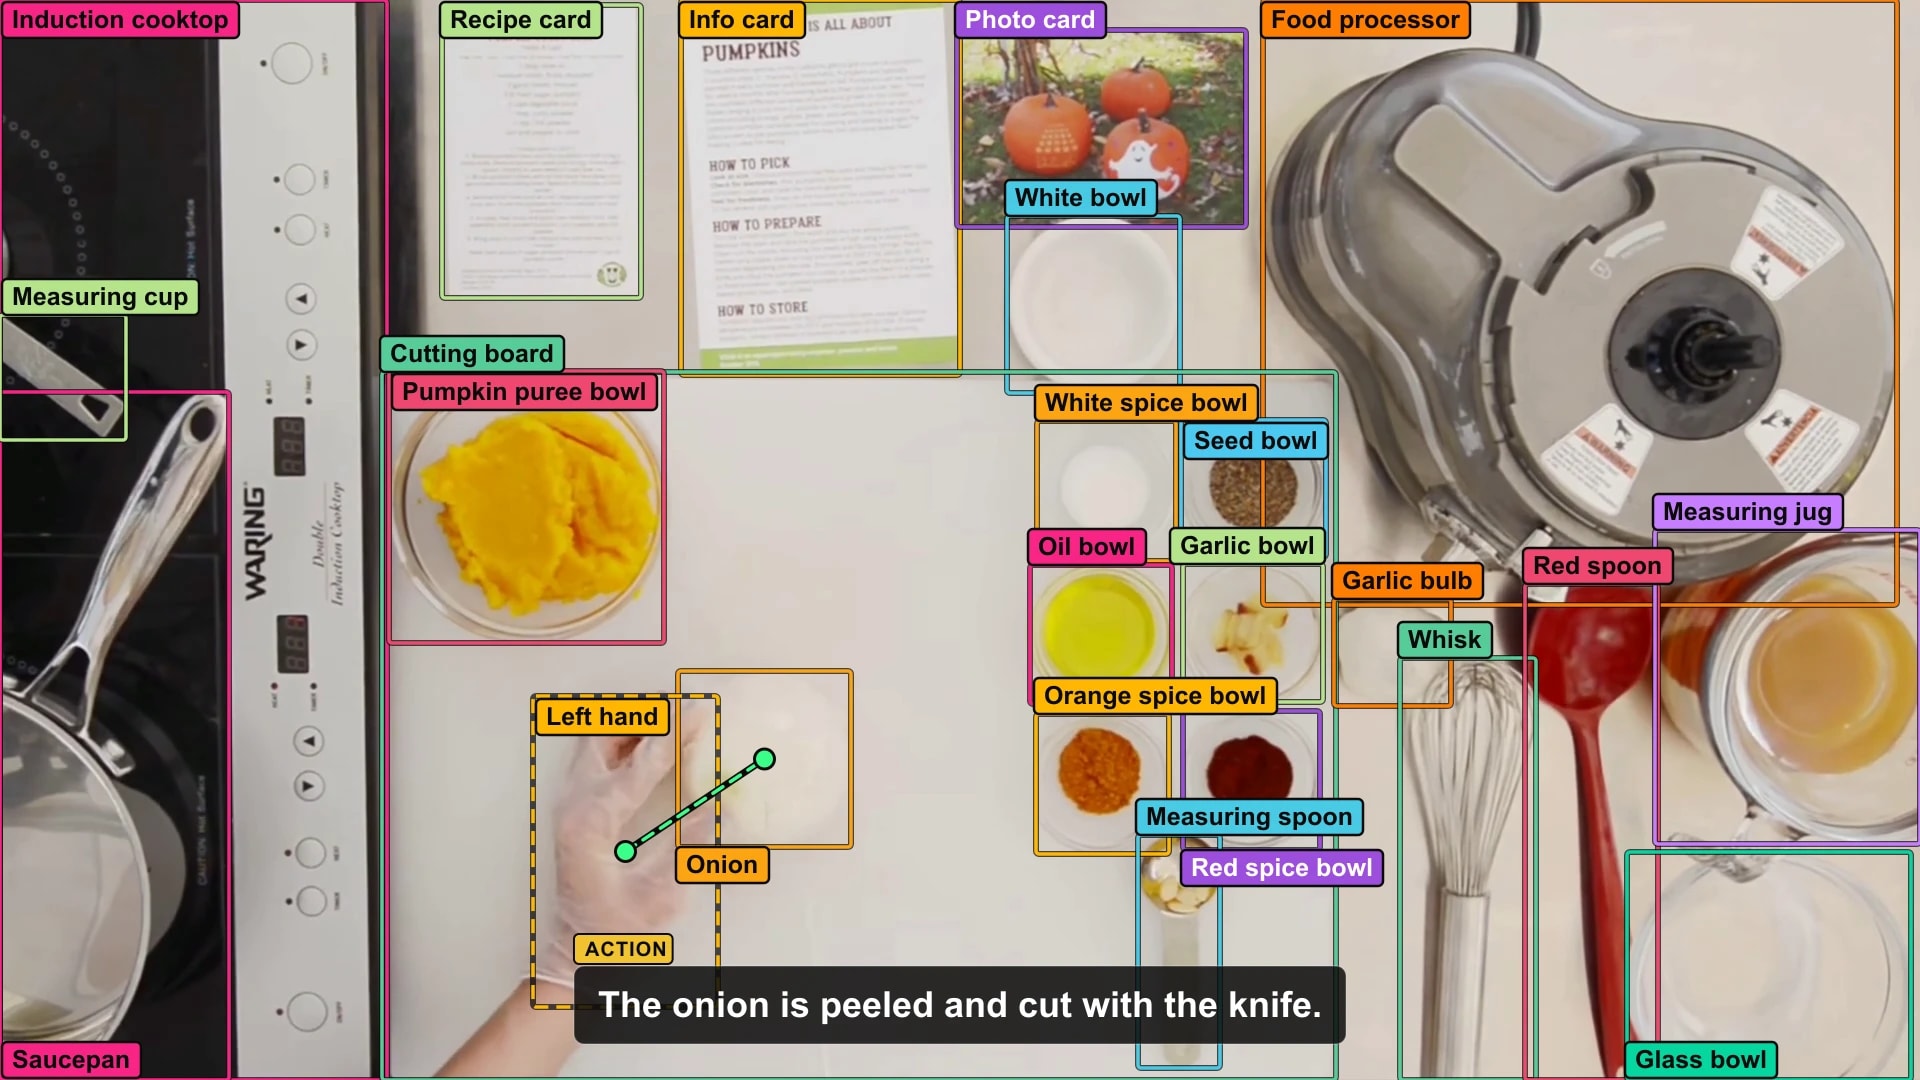
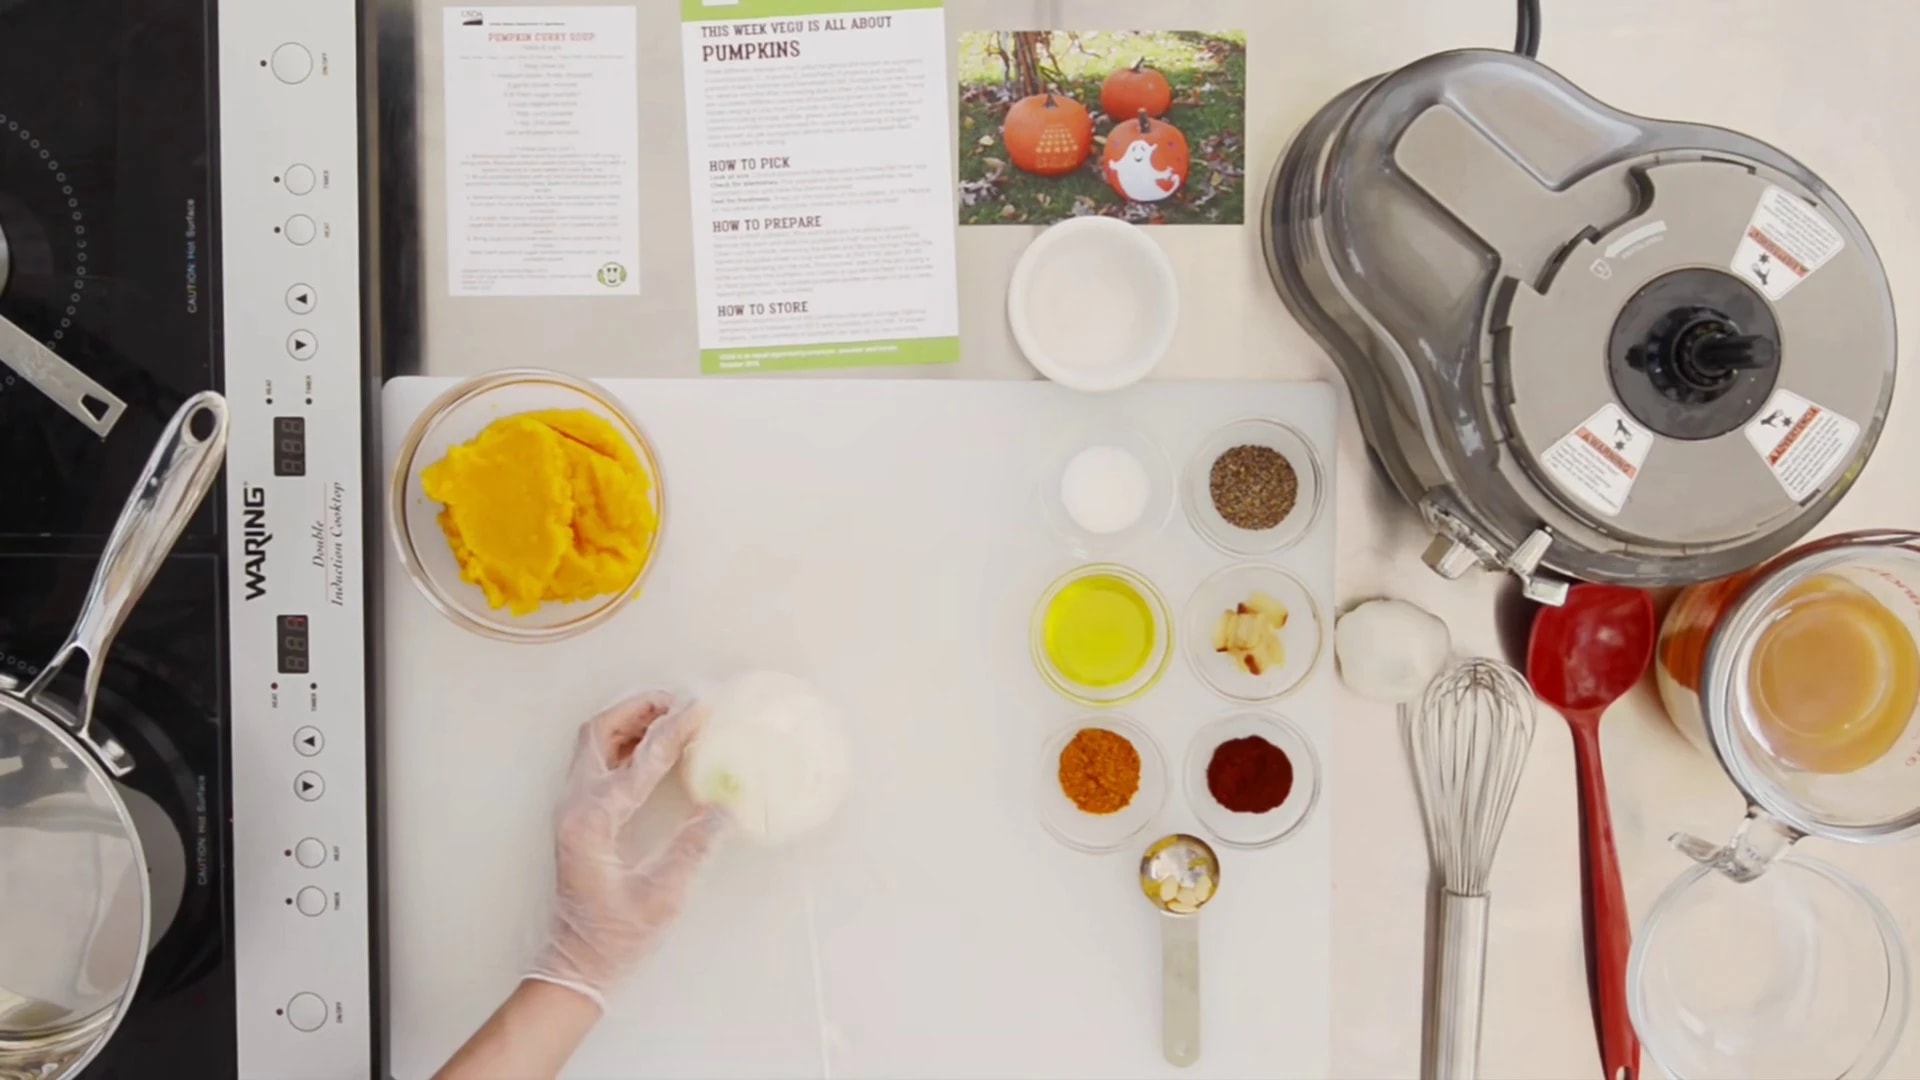
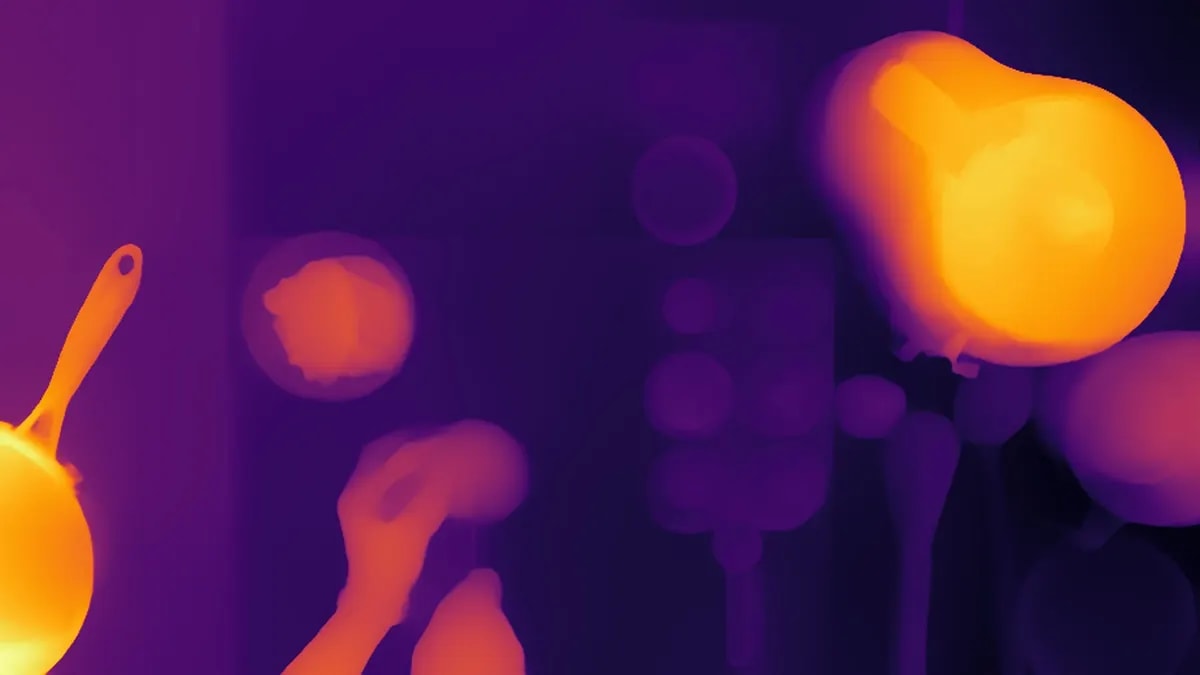
Pumpkin soup prep: 27 classes, 28 tracks and per-frame depth — raw frame and labeled output
RAWANNOROID

Pumpkin soup prep: 27 classes, 28 tracks and per-frame depth

Read case study

Drag to compare

Raw on the left. Ours on the right.

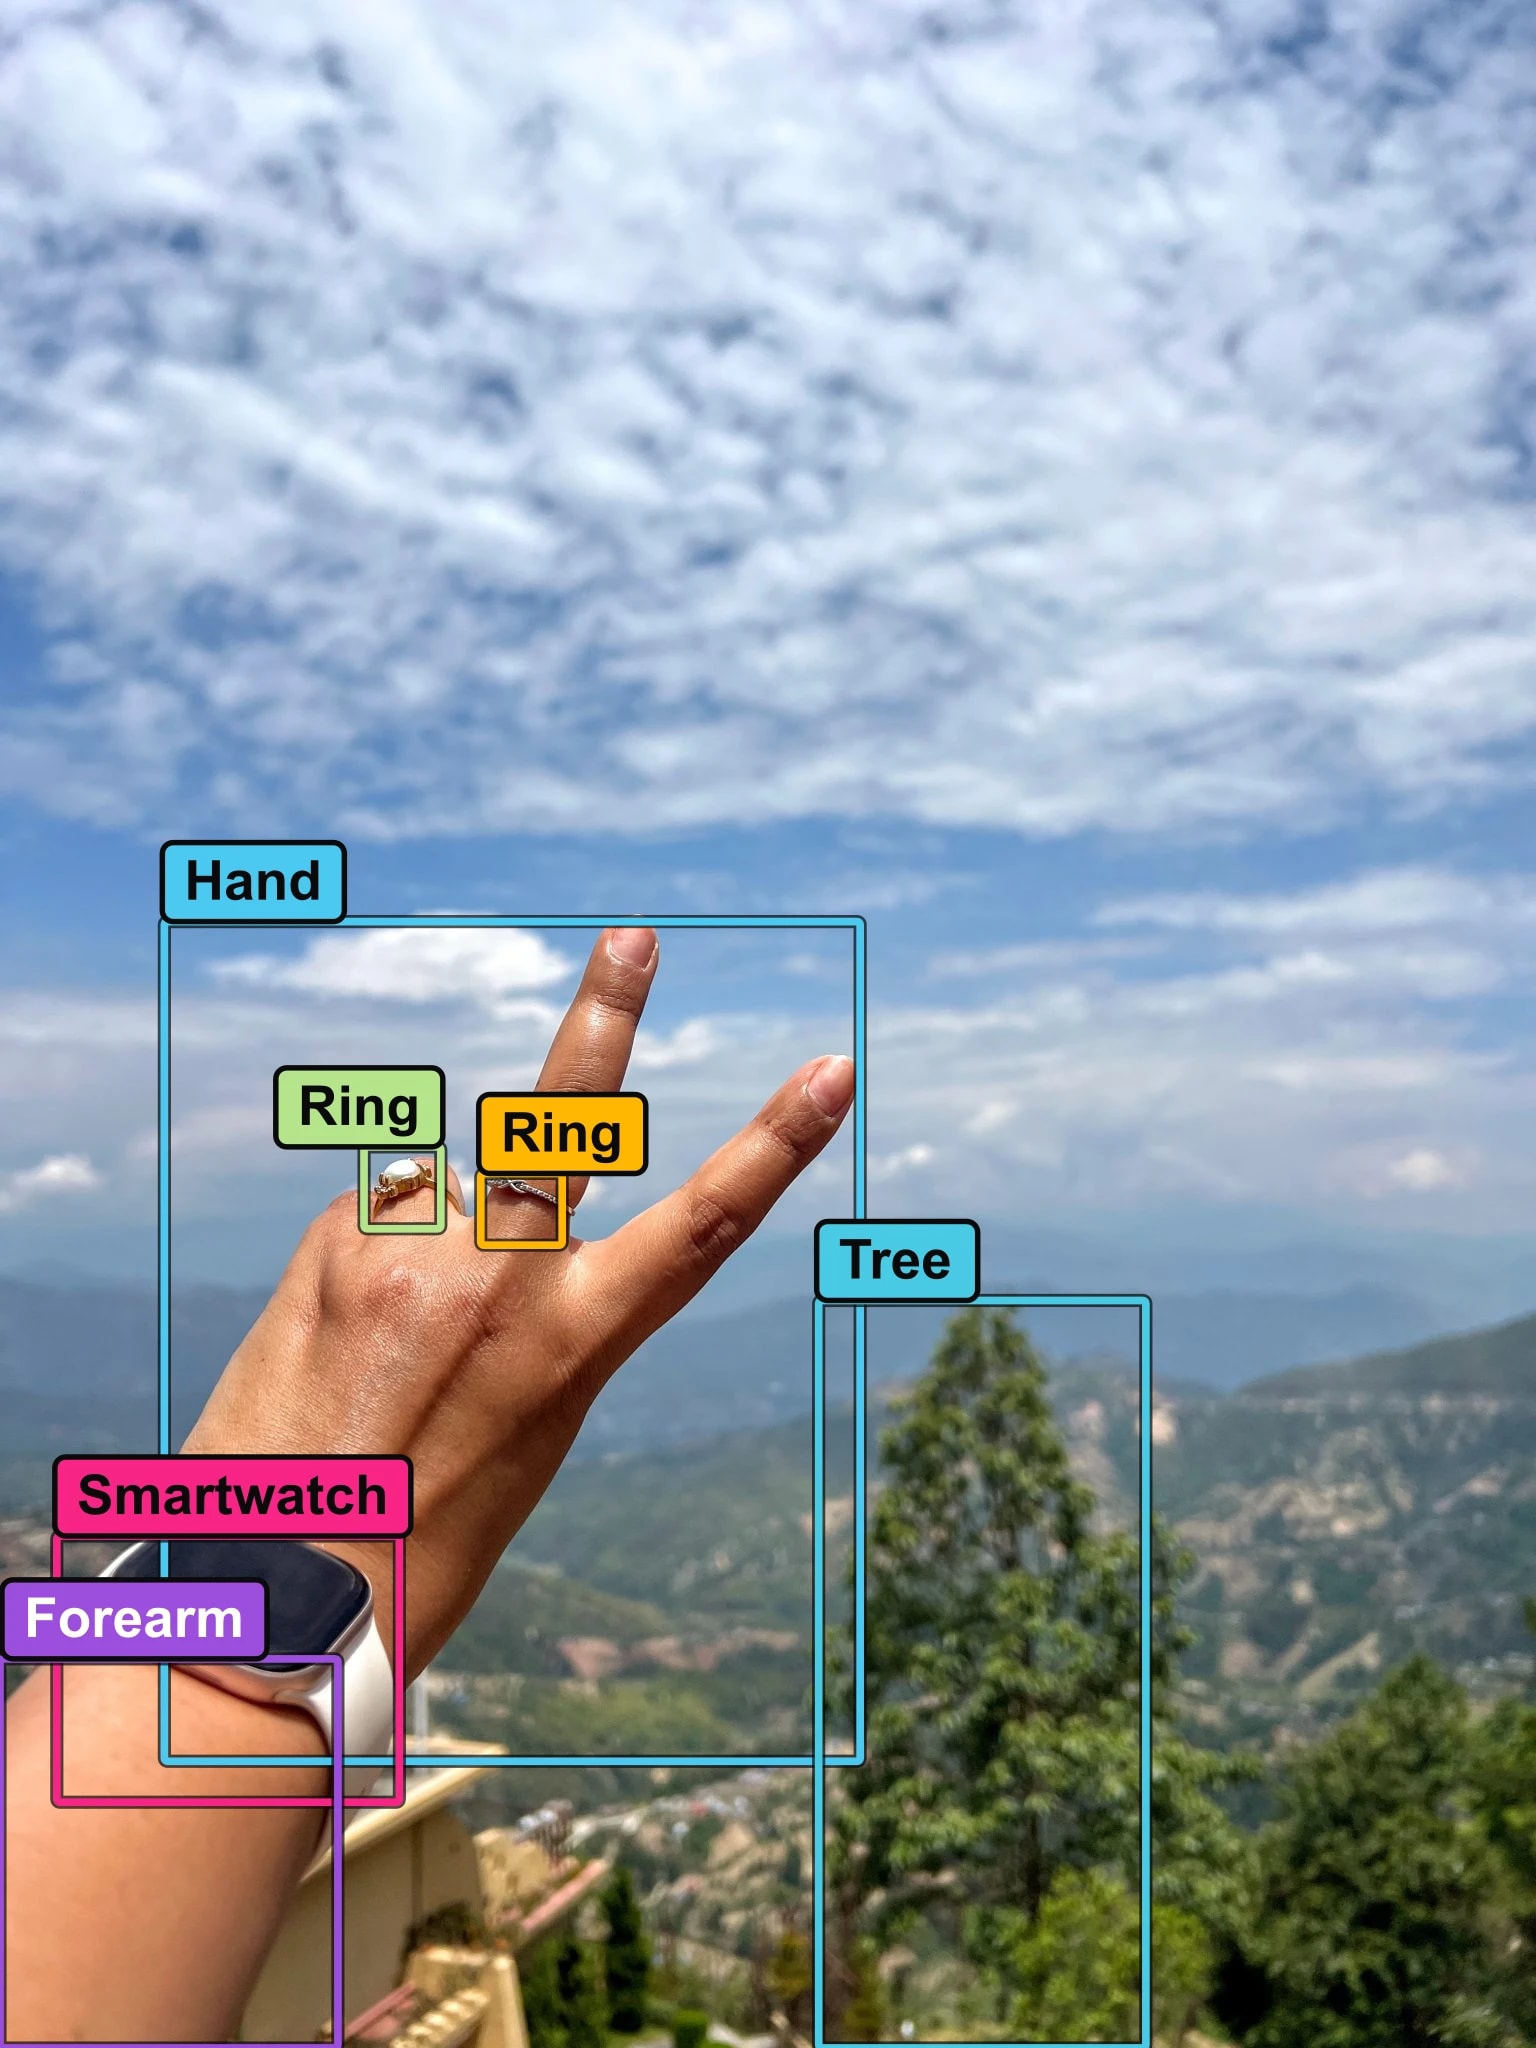
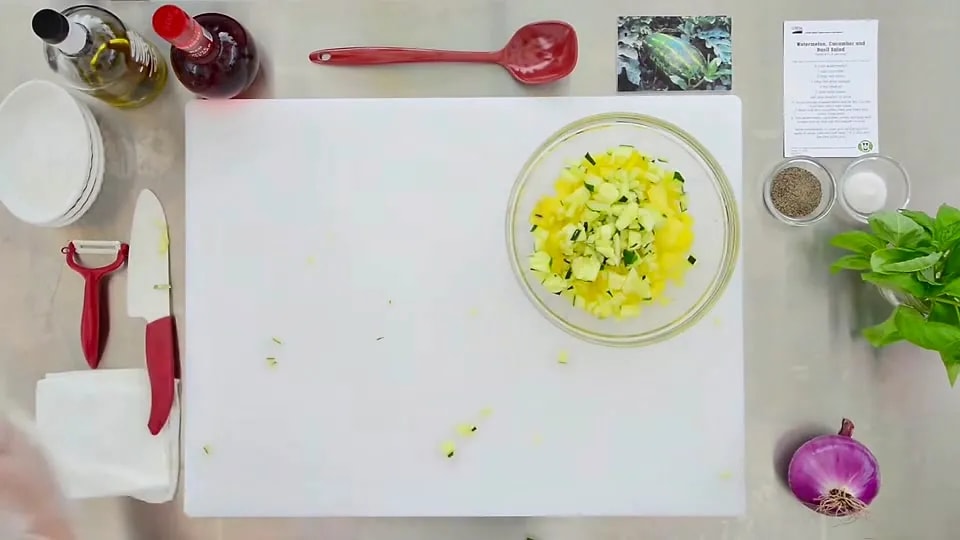
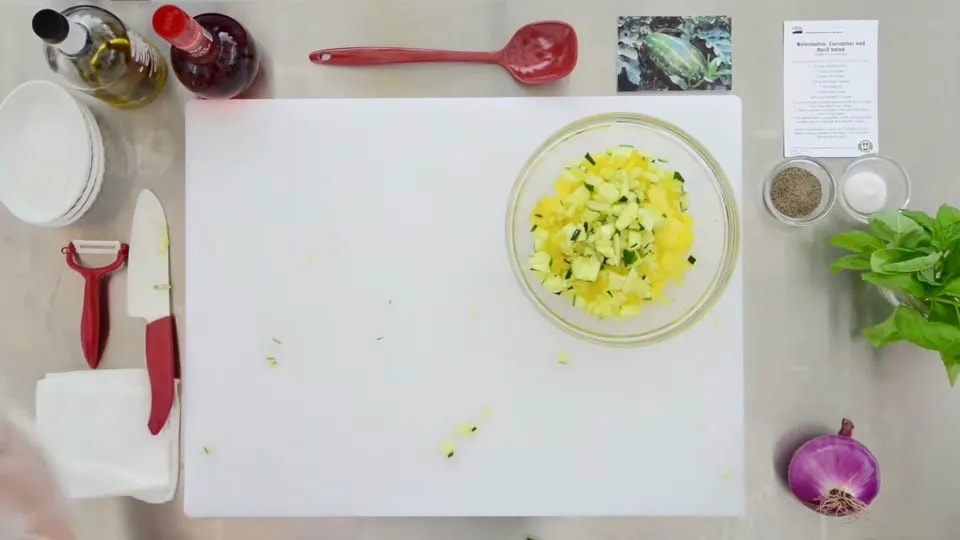
Watermelon salad · objects, hands and action — raw frame and labeled output
RAWANNOROID

Watermelon salad · objects, hands and action · drag the line or use ← → keys

All samples

Want to see this on your own data?

Judge the output yourself. The pilot is free, results come back in 48 hours, and there's no contract.